Description
Module 2: The 10-Second Procurement Snapshot
- Brand: ABB
- Full Model Number: DSQC313
- Related Part Numbers: 3HAB2213-1; 3HAB2213-1/2; 3HAB2213-1/3
- Lifecycle Status: Legacy / obsolete
- Core Function: Serial Measurement Board for ABB robots
- Product Type: Robot SMB / Measurement Board
- Top 3 Technical Specs: S4/S4C/S4C+ robot family; serial measurement interface; motor position feedback
- Typical Robot Platform: ABB IRB robot systems
- Stock & Condition: New Surplus / Tested Refurbished; confirm exact revision and inventory
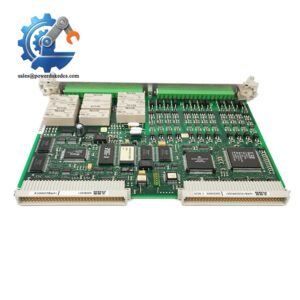
ABB references identify DSQC313 as a Serial Measurement Board (SMB) used with S4, S4C, and S4C+ robot systems. Part references include 3HAB2213-1 and related revision variants.
Module 3: Supply Chain & Technical Deep Dive
A failed SMB can stop an older ABB robot even when the mechanical arm and main controller remain serviceable. DSQC313 is the serial measurement board associated with ABB robot systems, handling measurement information required by the controller. It is documented for S4/S4C/S4C+ platforms, with 3HAB2213-1 listed as a corresponding ABB reference.
For maintenance inventory, this is an insurance spare rather than a routine consumption item. Keeping one tested board can avoid a much longer search when an aging robot cell goes down. Be careful with the suffix, though: field references show DSQC313 boards with 3HAB2213-1/2 and 3HAB2213-1/3 revisions, and the mounting configuration must match the robot application.
Module 4: Migration, Compatibility & Field Traps
Replacement Matrix
| Replacement Scenario | Assessment | Required Action |
|---|---|---|
| Same DSQC313 with matching 3HAB2213 revision | Drop-in Replacement Candidate | Match complete SMB assembly and mounting configuration |
| DSQC313 with a different revision suffix | Compatibility Check | Confirm revision and robot application |
| DSQC313 used on a different IRB model | Application Check Required | Verify SMB assembly and mechanical mounting |
| Different SMB family | Not Automatically Compatible | Check robot controller, wiring, and measurement system |
⚠️ Field Traps: Watch Out
Revision suffix matters. A field reference specifically discusses DSQC313 assemblies marked 3HAB2213-1/2 and 3HAB2213-1/3 and notes that the board is used in different SMB mounting configurations. Do not approve a replacement from the DSQC313 name alone.
Check the complete SMB assembly. The board is installed within an SMB assembly, so compare the mounting arrangement and associated part number before removal.
Motor feedback wiring: Photograph every connector and wire position. Do not rely on memory when reconnecting measurement signals.
Robot calibration: After replacement, verify the robot’s measurement and calibration status before returning it to automatic production.
ESD: Use a grounded wrist strap and ESD-safe work surface when handling the board.
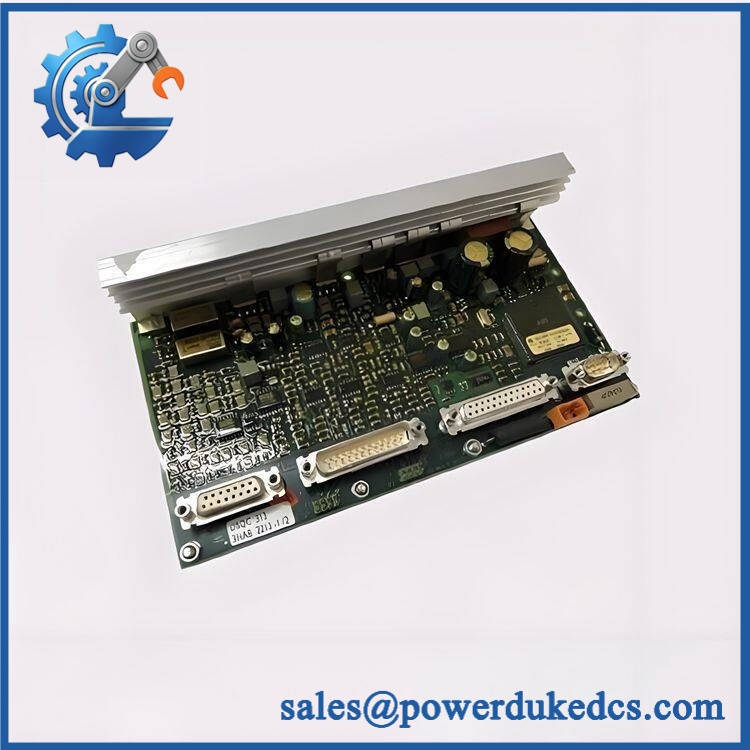
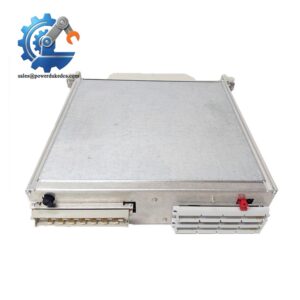
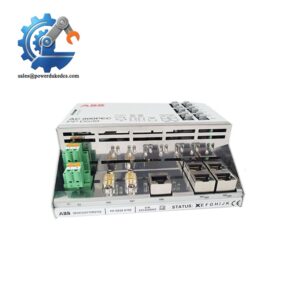
ABB DSQC313
Module 5: Quality Assurance & Testing SOP
1. Incoming Inspection
- Verify ABB identification.
- Confirm DSQC313 marking.
- Record the complete 3HAB part number.
- Record revision suffix.
- Inspect PCB and connectors.
- Check for corrosion, burn marks, cracks, or repair evidence.
- Inspect measurement connectors and contacts.
- Photograph the nameplate and PCB.
2. OEM Authenticity Inspection
- Check ABB/Bailey? No — this is an ABB Robotics assembly.
- Verify ABB identification labels.
- Compare PCB layout with an approved reference.
- Check connector arrangement.
- Compare revision markings.
- Inspect soldering and visible component condition.
- Record available traceability information.
3. Power-On / Controller Test
Using a compatible ABB S4/S4C/S4C+ robot test environment:
- Install the SMB in the correct test assembly.
- Apply the specified controller power.
- Check controller recognition.
- Monitor diagnostic indications.
- Confirm measurement-board initialization.
- Record any robot controller diagnostic codes.
4. Measurement Function Test
Where the correct robot test setup is available:
- Verify measurement-board communication.
- Check motor measurement feedback.
- Exercise applicable robot axes.
- Monitor position feedback.
- Check for measurement errors.
- Confirm stable feedback during controlled axis movement.
Do not apply generic voltage or signal values to the measurement inputs. Use the ABB documentation for the specific robot and SMB assembly.
5. Extended Functional Test
A suitable test stand should verify:
- Controller communication.
- Measurement feedback.
- Axis response.
- Diagnostic status.
- Repeated startup behavior.
- Stable operation during an extended test.
The Test Report should record the DSQC313 part number, complete 3HAB reference, revision, serial number, robot/controller platform, test duration, diagnostic results, and measurement-test results.
6. Final QC & Packaging
- QC inspection signed.
- ESD-safe bag sealed.
- Connector protection installed.
- Shock protection added.
- QC label applied.
- Test documentation retained with the inventory record.
Test photographs or video can be supplied when available.
Module 6: Procurement-Driven FAQ
1. Is ABB DSQC313 available for immediate shipment?
Physical inventory should be confirmed against the actual warehouse unit. For an urgent robot-cell repair, request the complete 3HAB part number, revision, condition, test status, quantity, and shipping cutoff before placing the order.
2. How do you verify an obsolete DSQC313?
The board should pass visual inspection, identification checks, connector inspection, and functional testing in a compatible ABB robot environment where available. The test record should identify the exact revision rather than simply stating “DSQC313.”
3. Can 3HAB2213-1/2 replace 3HAB2213-1/3?
It may be possible, but do not treat the suffixes as automatically interchangeable. A field reference reports that /2 should work in a particular IRB6400 application, while also stressing that the SMB mounting configuration must match. For procurement approval, match the robot model, SMB assembly, and complete part number.
4. What warranty should I request for a refurbished DSQC313?
Request written terms covering the warranty period, failure evidence, return procedure, and replacement or refund conditions. The warranty should apply to the complete tested unit supplied, not merely the PCB label.
5. What should engineers check before installing the replacement?
Record the robot model, controller type, complete SMB part number, revision suffix, connector positions, and existing diagnostic status. Photograph the wiring before removal. After installation, verify measurement feedback and robot calibration status before returning the cell to automatic operation.

 Start Chat